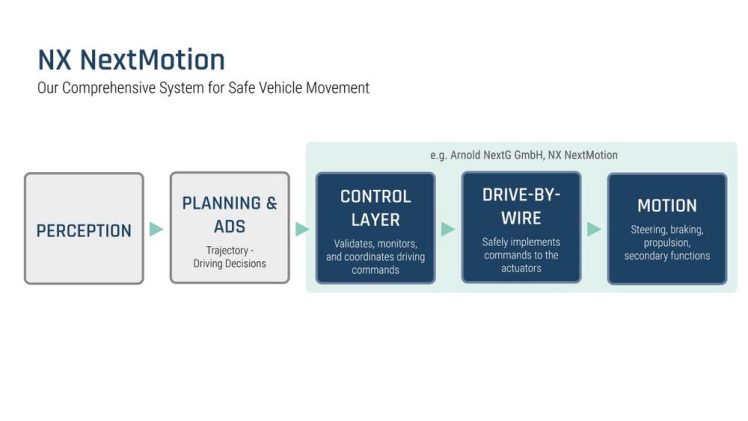
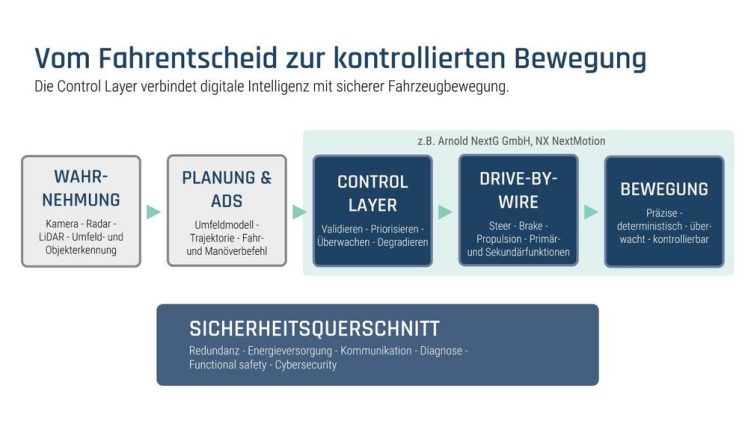
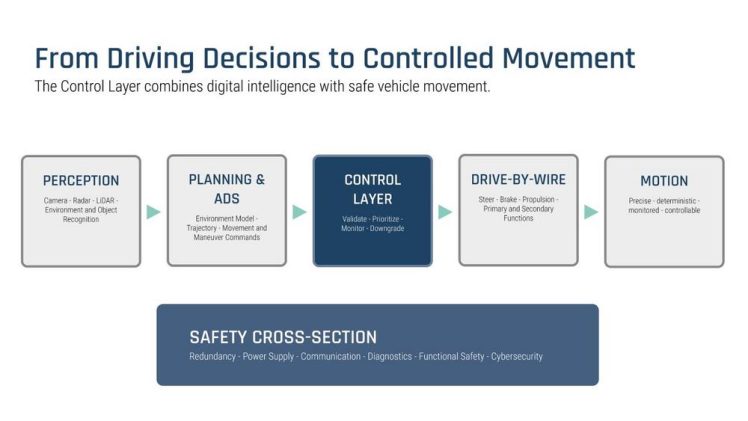
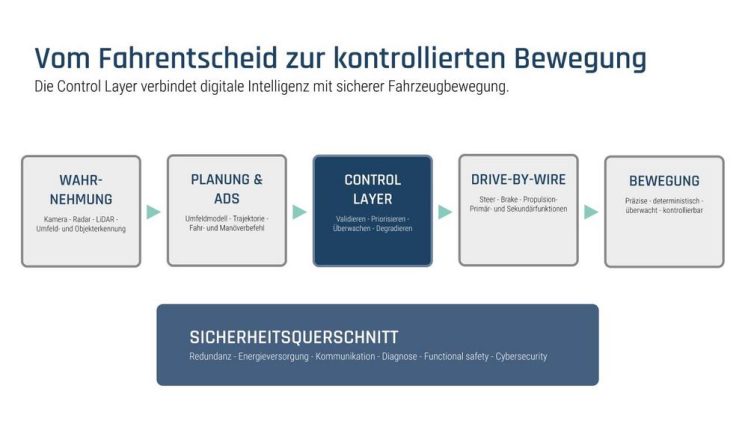
Autonomous and remotely controlled vehicles place new demands on vehicle architecture. Where steering, braking, and propulsion are electronically controlled, control over vehicle movement must be ensured at all times—even in the event of a fault. This makes drive-by-wire a safety-critical control layer between the driving command and vehicle motion. Whether the command comes from an […]
Read More